Our research group is constantly looking for top PhD and Postdoc students. If you are interested in joining us, send an email to jtordesillas@comillas.edu
RESEARCH

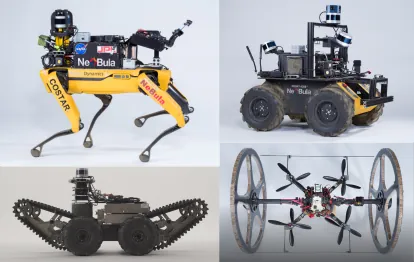
We work on learning-based trajectory planning: training neural networks to produce onboard, in milliseconds, the motions a classical planner needs seconds to compute, and to keep doing so outside the simulator they were trained in. Tied closely to this is our work on imposing hard constraints on neural networks, so that a learned policy satisfies safety and dynamic limits by construction — for any weights and any input — rather than merely being penalised when it breaks them, which is what allows a learned planner to inherit the guarantees its classical counterpart came with. We also work on optimization-based trajectory planning, both in its own right and as the source of the supervision and the guarantees the learned methods are asked to preserve. Most of this flies, on aerial robots moving through unknown, cluttered and dynamic environments, and increasingly walks, on legged robots — along with the state estimation all of it rests on.
PUBLICATIONS View .bib

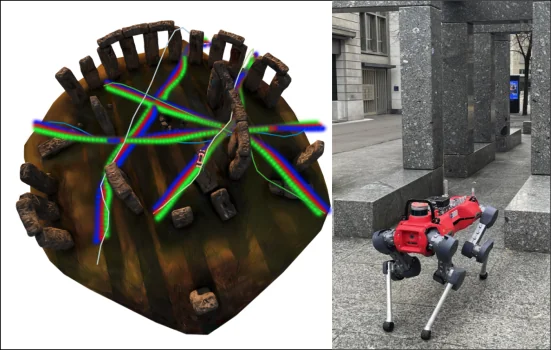
A quadrotor trajectory optimized directly through a Gaussian-splat reconstruction of a cluttered scene.

FOCI

Trajectory Optimization on Gaussian Splats
Paper Project Code IROS 2025

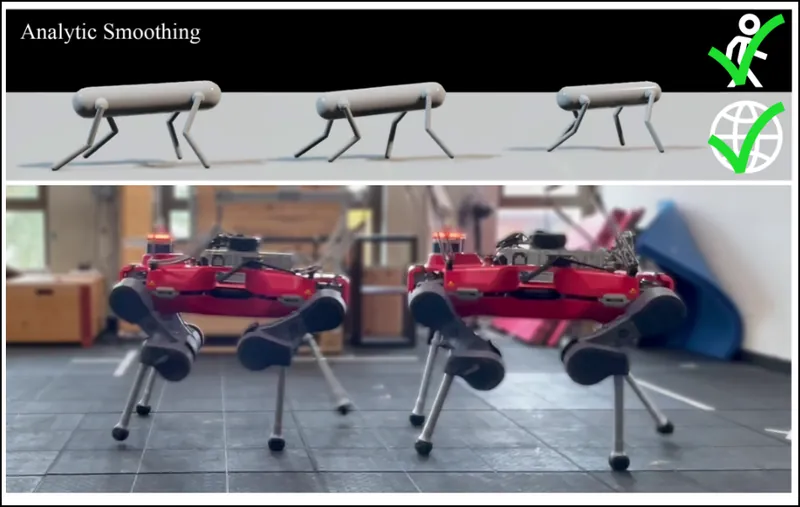
A quadruped walking under a control policy trained entirely inside a differentiable simulator.

DiffSim2Real

Deploying Quadrupedal Locomotion Policies Purely Trained in Differentiable Simulation
Paper DiffOpt, CoRL 2024
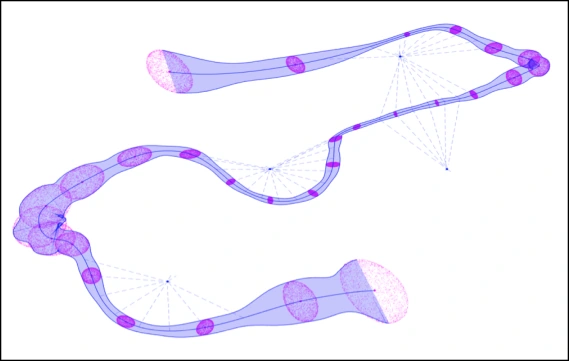
Taxonomy diagram comparing discrete-time and continuous-time formulations for robot state estimation.

Continuous-Time State Estimation

Continuous-Time State Estimation Methods in Robotics: A Survey
Paper T-RO
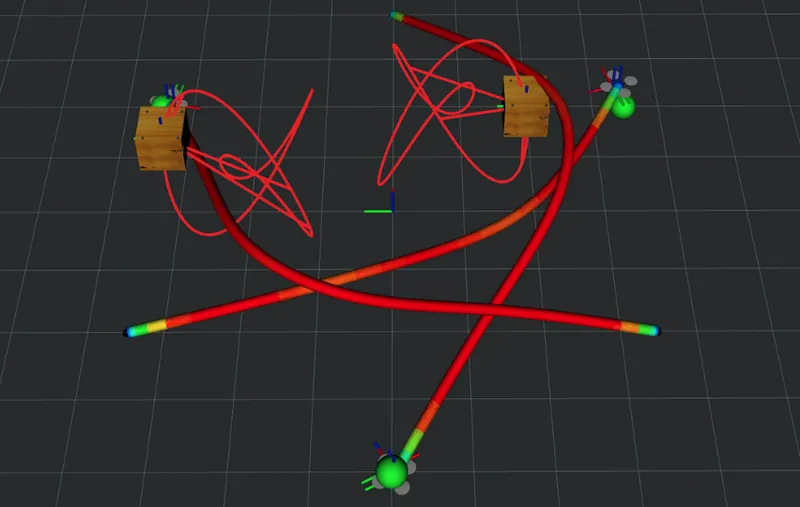
Several quadrotors flying through a shared space, each tracking the others with onboard cameras.

PRIMER

Perception-Aware Learning-based Multiagent Trajectory Planner
Paper ICRA 2025
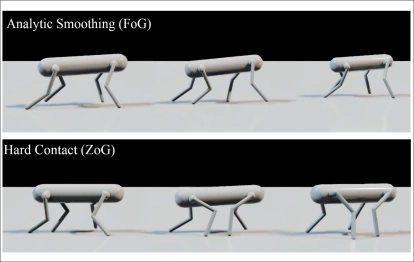
Gradient flow through a differentiable contact model used to train a quadrupedal locomotion policy.

Differentiable Simulation

Learning Quadrupedal Locomotion via Differentiable Simulation
Paper Video In review

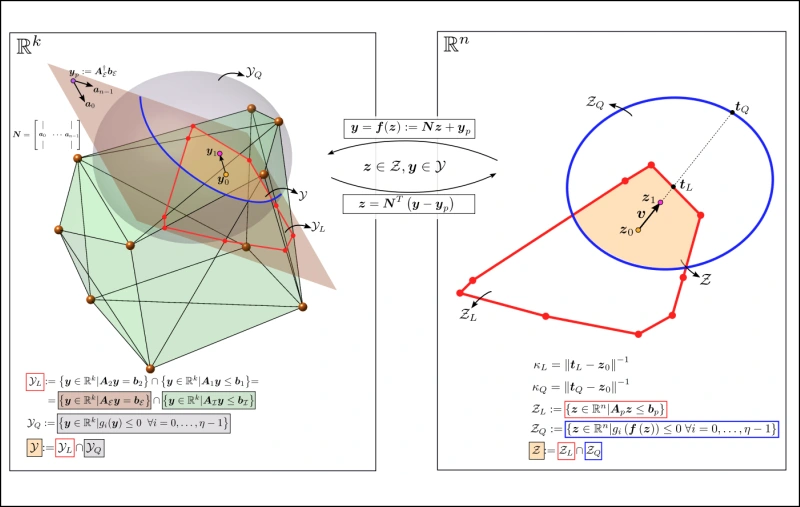
Diagram of the RAYEN layer projecting a neural network output onto a convex feasible set along a ray.

RAYEN

Imposition of Hard Convex Constraints on Neural Networks
Paper Code In review

Title slide of the tutorial linking convex optimization, optimal control and spline parameterizations.

Tutorial

Optimization, Optimal Control, Trajectory Optimization, and Splines
Video
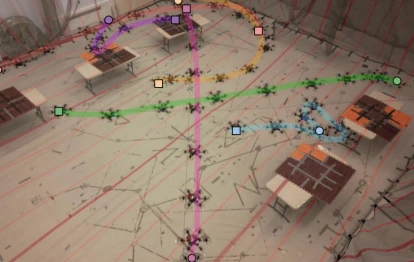
Two quadrotors negotiating overlapping trajectories despite delayed communication between them.

RMADER Planner

Decentralized and Asynchronous Multiagent Trajectory Planner Robust to Comm. Delay
Best Poster Award in CAMRS Workshop (ICRA)
RA-L Paper ICRA Paper Video Code RA-L and ICRA 2023
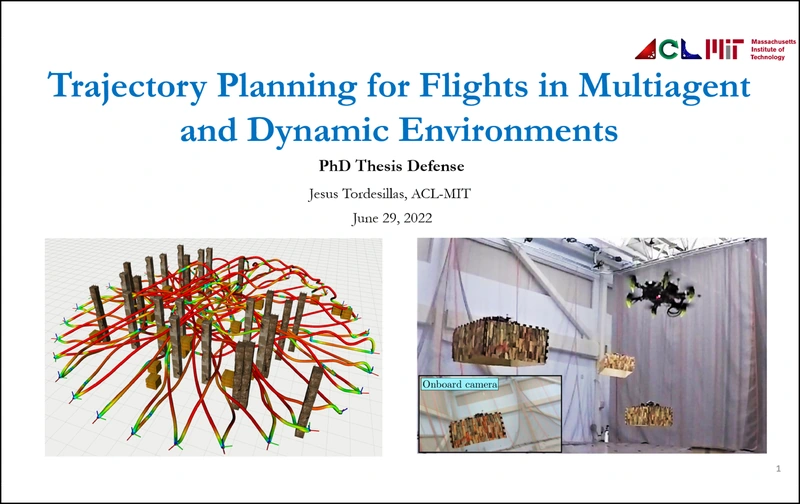
Jesus Tordesillas presenting the final slide of his PhD defense at MIT.

PhD Thesis

Trajectory Planning for Flights in Multiagent and Dynamic Environments
Video of the defense Dissertation
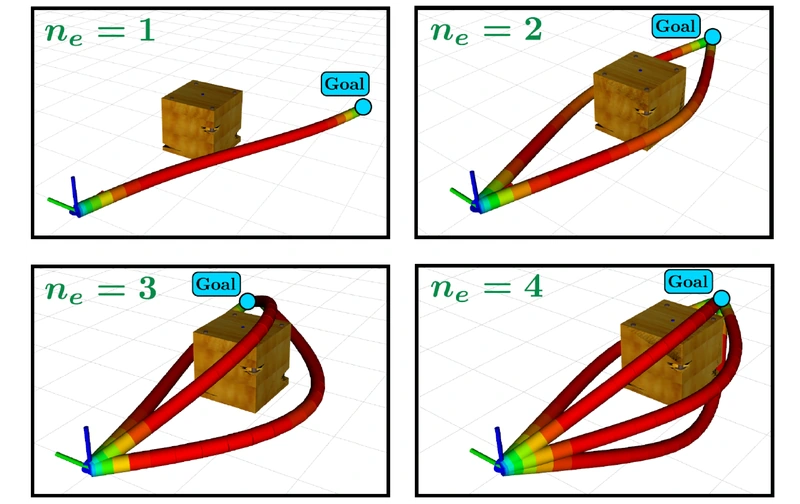
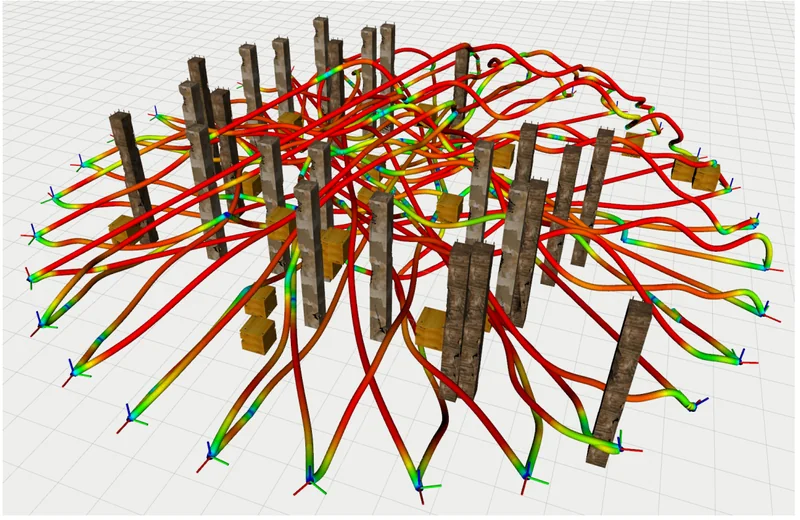
A learned planner producing candidate trajectories around a moving obstacle in a single forward pass.

Deep-PANTHER Planner

Deep-PANTHER: Learning-Based Perception-Aware Traj. Planner in Dynamic Enviroments
Paper Video Code RA-L

PANTHER Planner

Perception-Aware Trajectory Planner in Dynamic Environments
Paper Video Code IEEE Access

Several quadrotors exchanging trajectories in flight to cross a shared workspace without collisions.

MADER Planner

Trajectory Planner in Multi-Agent and Dynamic Environments
Paper Video Code T-RO

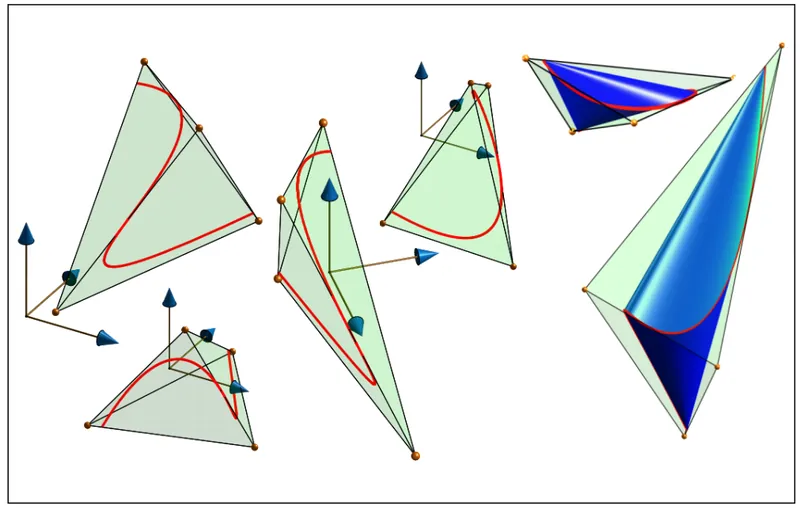
A polynomial curve enclosed by the minimum-volume simplex given by the MINVO basis.

MINVO Basis

Finding Simplexes with Minimum Volume Enclosing Polynomial Curves
Paper Video Code CAD journal

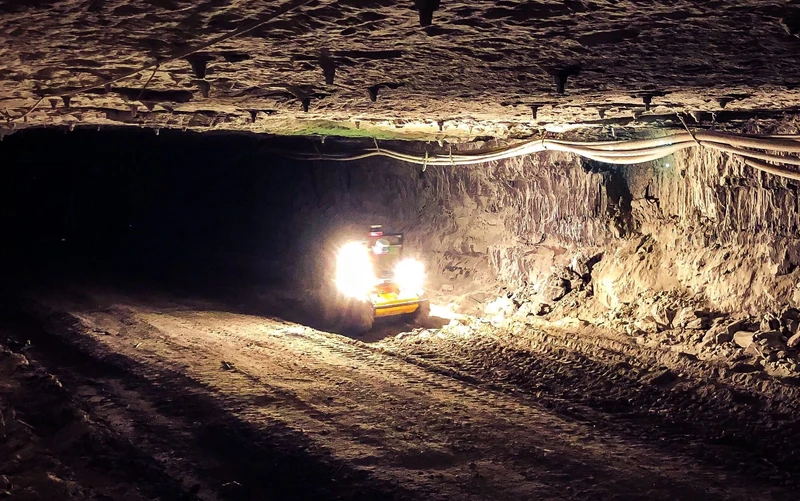
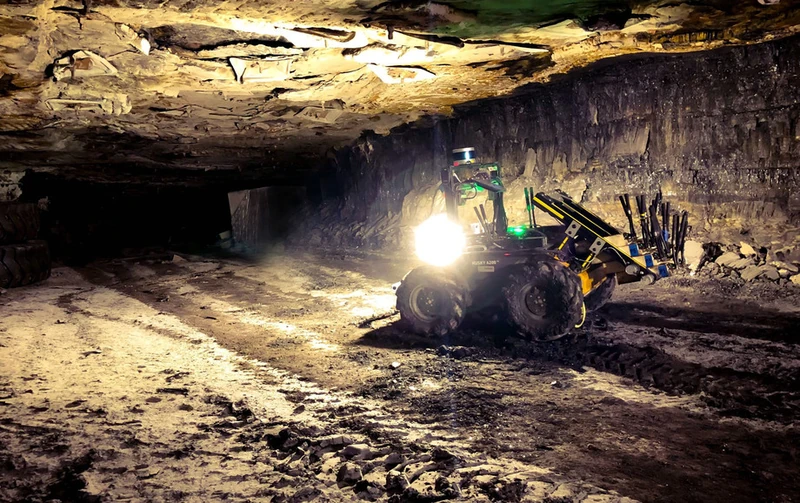
A robot carrying a lidar payload 275 metres underground in a West Virginia mine. Mine in West Virginia, 275 meters underground

LION Estimator

Lidar-Inertial Observability-Aware Navigator for Vision-Denied Environments
Paper Video ISER 2020

A robot traversing loose rubble in an unlit underground mine passage. Mine in West Virginia, 275 meters underground

Traversability

Autonomous Navigation in GPS-Denied and Perceptually-Degraded Environments
Paper Video ISER 2020

FASTER Planner

Fast and Safe Trajectory Planner for Navigation in Unknown Environments.
Finalist: Best Paper Award in Search and Rescue Robotics
IROS Paper T-RO Paper Video Code T-RO and IROS 2019
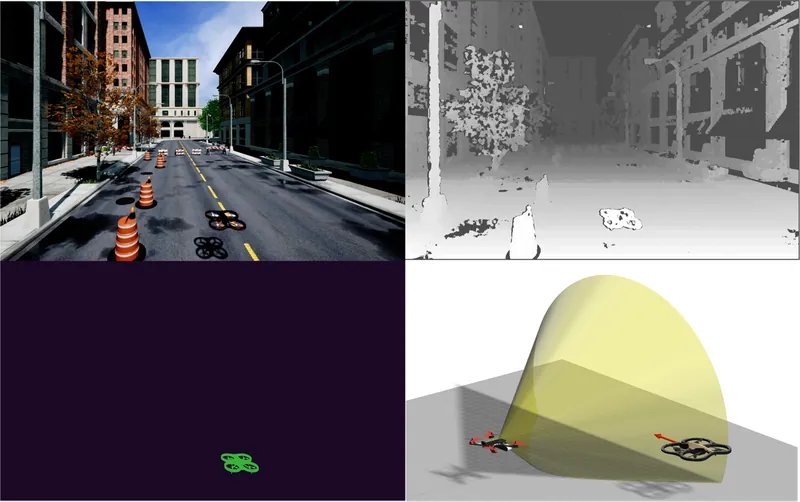
Depth image with a second drone segmented and localized in 3D by the onboard detector.

Drone detection using depth maps

Onboard Detection and Localization of Drones Using Depth Maps.
Paper Video IEEE Access 2020

A quadrotor planning with a coarse long-horizon model and a fine short-horizon model at once.

Multi-Fidelity Planner

Real-Time Planning with Multi-Fidelity Models for Agile Flights in Unknown Environments.
Paper Video Code ICRA 2019

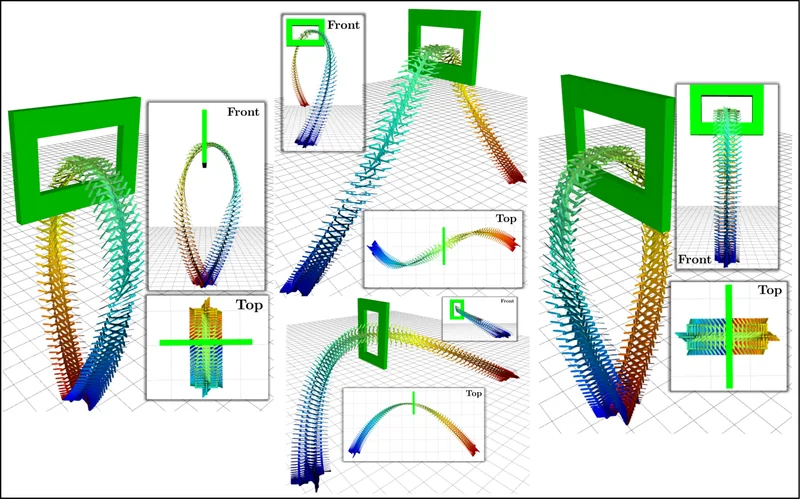
Optimized acrobatic multirotor trajectory including a full flip.

Trajectory Optimization

Trajectory optimization for multirotors using Gurobi
Paper Video Code

Drone Racing

Trajectory optimization using GPOPS-II
Thesis Video Code Master’s Thesis

Aerial Manipulation

Agile Plate Transport with a Hexacopter with Canted Motors.
Video
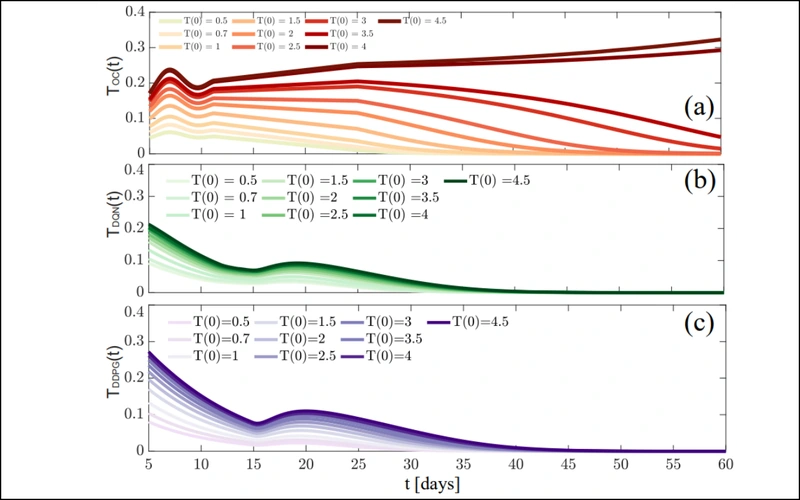
Tracking-error curves for four adaptive controllers applied to the same multirotor model.

Adaptive Control for a Multirotor

TEB, CG, BFG and CF adaptive controllers
Paper Code

Performance and robustness curves comparing a model-based controller against a model-free policy.

Reinforcement Learning vs Opt. Control

A numerical comparison of performance and robustness in model-based and model-free methodologies.
Paper
Finite Element Simulation for C-Legs

Finite Element Simulation for C-Legs using Autodesk Simulation Mechanical.
Thesis Video Undergraduate thesis

Hexapod Design

3D design of a hexapod robot using Autodesk Inventor.
Plans Video Undergraduate thesis

Gait Models for a Hexapod Robot

Analysis of different gaits Models applied to a hexapod robot with C-Legs.
Thesis Video Undergraduate thesis

Robot Kinematics with C-Legs

Kinematic model of a hexapod robot with C-Legs. Simulations with Autodesk Inventor.
Paper Video Jorn. de Automática 2016

Test Bench for C-Legs

Test Bench to tests C-Legs built using and Arduino Mega and drivers L298N.
Thesis Video Undergraduate thesis

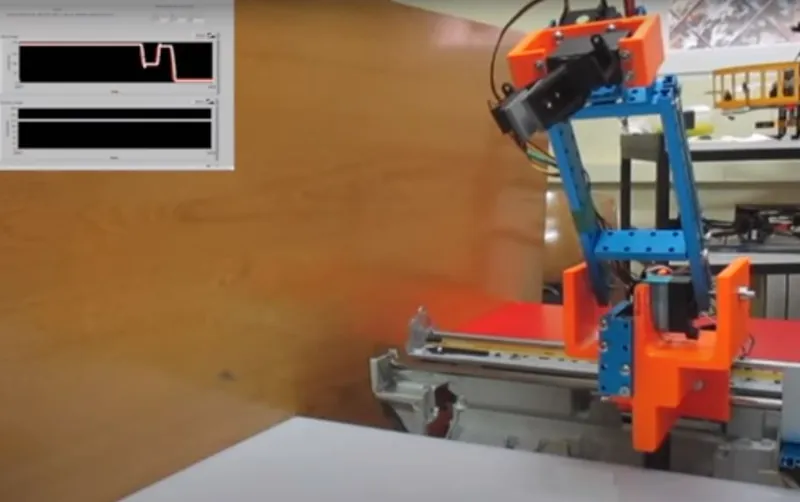
Bench-built robotic arm driven by an Arduino and a LabVIEW front panel.

Robotic Manipulator

Robotic Manipulator design and building using Arduino and LabView.
Video
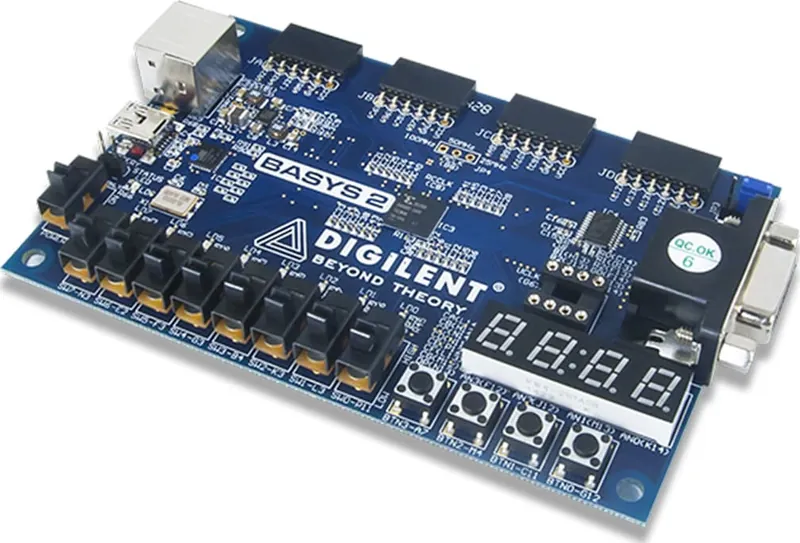
FPGA development board wired up for the VHDL schematic implemented in this project.

FPGA and VHDL

Schematic design and implementation on a FPGA.
Schematic designed